YZIT / PRODUCT
HEXA X1
Six-legged hexapod robot
HEXA X1 is a six-legged robot platform. Hexapod describes its six-leg structure; it is not a bipedal robot. This presentation focuses on the relationships between mechanics, electronics, fabrication and control.
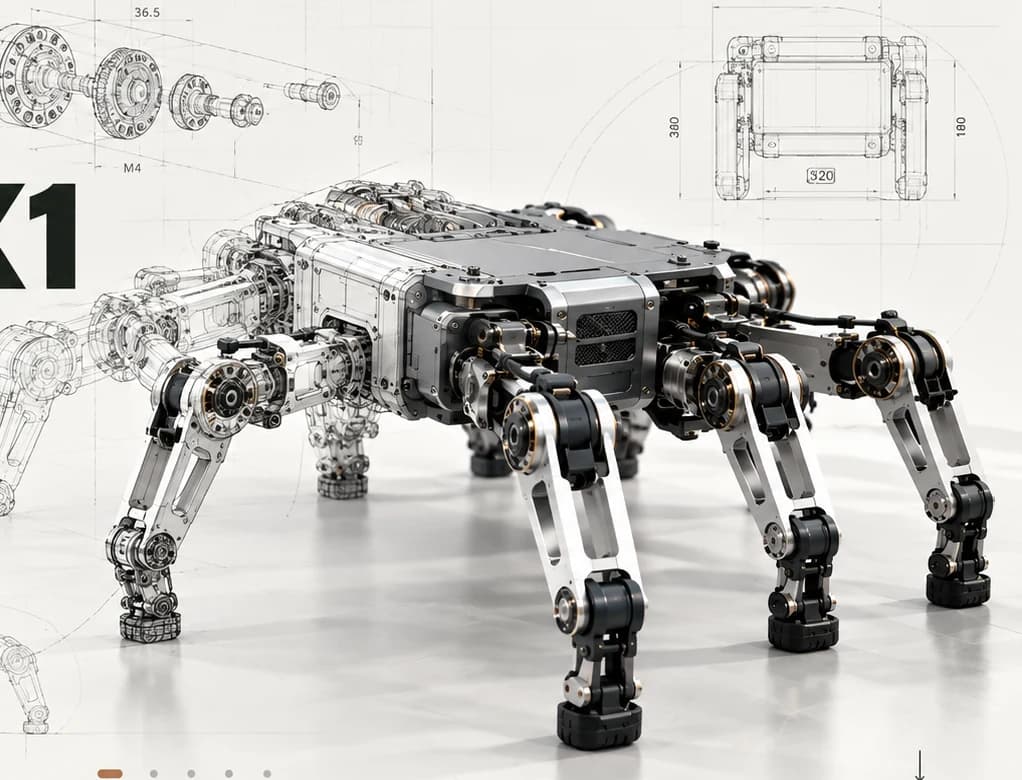
Structure and system relationships
The hexapod engineering framework covers structural concepts, SolidWorks 3D modeling, PCB design, component fabrication, mechanical assembly, power and electronics integration, and control testing. It connects individual component design with the implementation of a physical system.
From design to verification
The website uses a hexapod robot as a framework for explaining design, fabrication, assembly, motion testing and iteration. The imagery is an engineering illustration, not verified project photography. Detailed project information and its publication scope remain subject to confirmation.